Fourier GR-3 vs. EngineAI SE01
Fourier GR-3 and EngineAI SE01 are full-size humanoid robots built for different roles. We compare their speed, runtime, degrees of freedom, perception, manipulation and target applications.

October 2, 2026 by Business Desk Team
Introduction
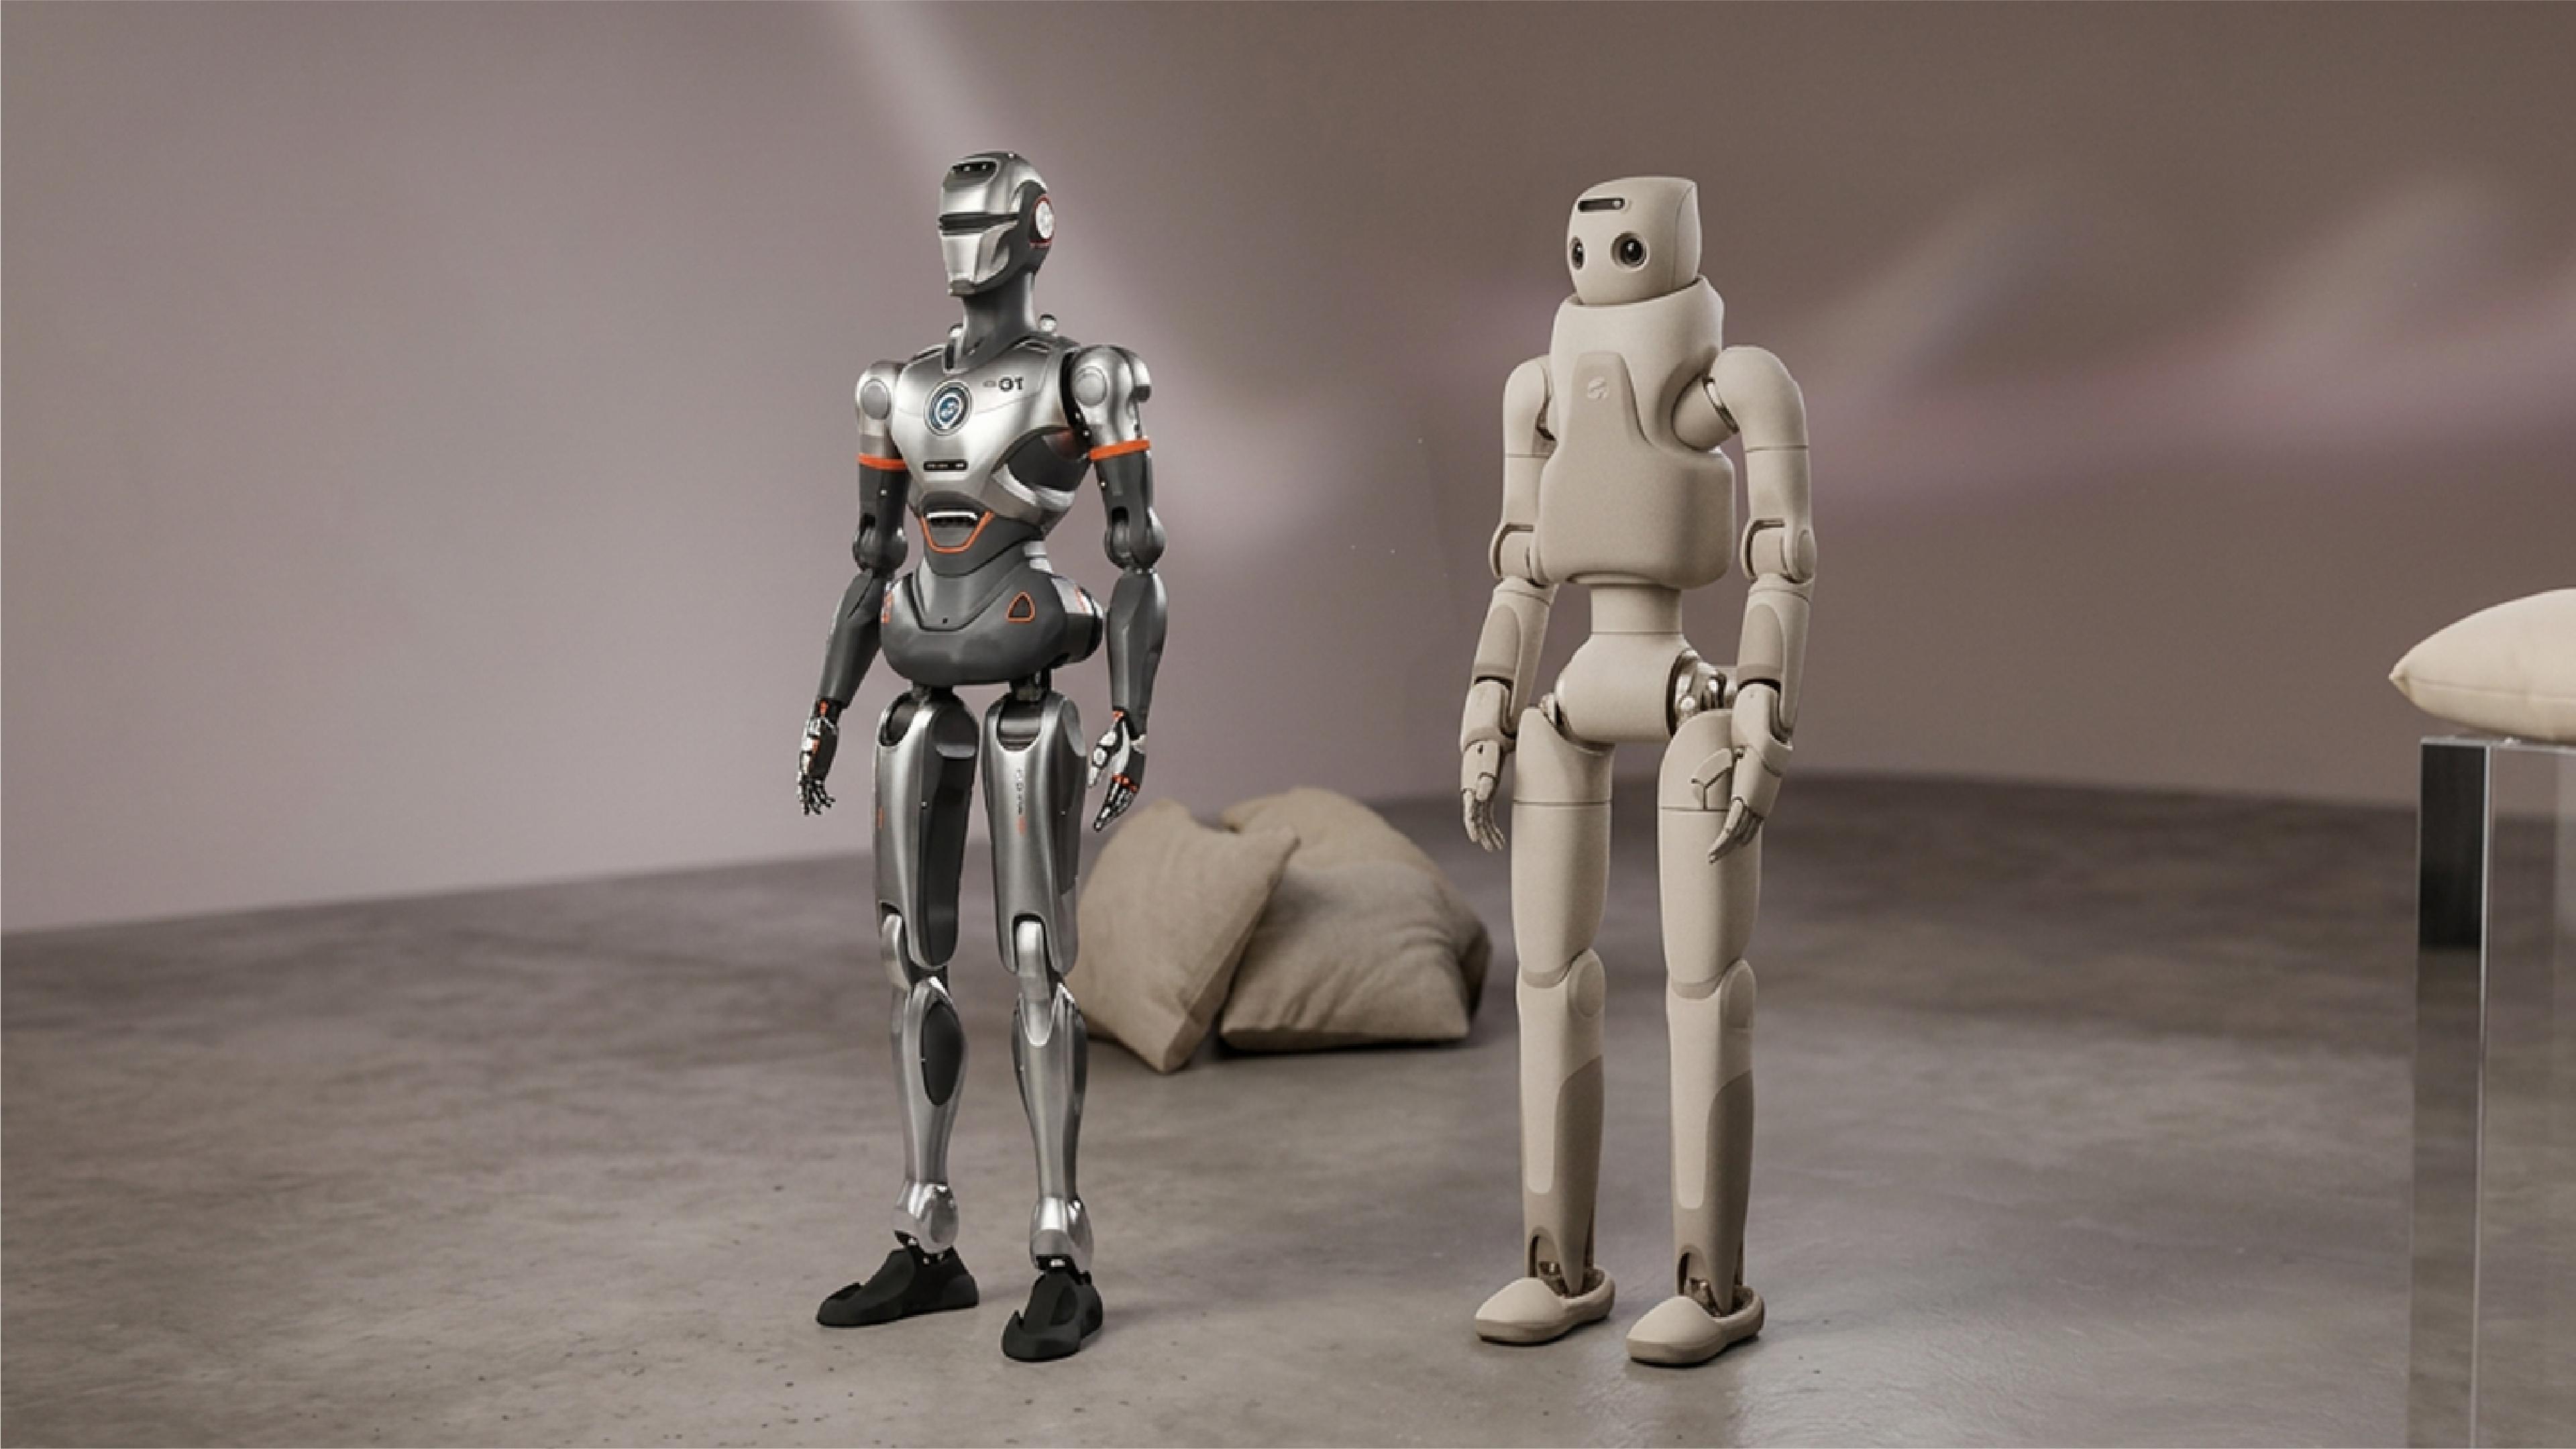
Fourier GR-3 and EngineAI SE01 are both full-size bipedal humanoid robots, but they target somewhat different applications.
Fourier GR-3 is a full-size humanoid designed around interactive companionship, embodied AI and human-robot interaction, with Fourier positioning the model as its first “Care-bot.” Its potential applications include public-service environments, research, human-robot interaction and care-oriented settings.
EngineAI SE01 is a full-size bipedal humanoid designed for applications including manufacturing, logistics, research and education.
The main documented differences are in their physical configuration, degrees of freedom, locomotion, runtime, perception systems and intended applications.
At a Glance
| Metric | Fourier GR-3 | EngineAI SE01 |
|---|---|---|
| Robot type | Full-size bipedal humanoid / Care-bot | Full-size bipedal humanoid |
| Use cases | Interactive companionship; public services; embodied AI; research; human-robot interaction | Manufacturing; logistics; research; education |
| Height / dimensions | 1642 × 552 × 292 mm (~165 cm tall) | 170 cm |
| Weight | ~71 kg | 55 kg |
| Degrees of freedom | Up to 55 DOF with optional 12-DOF dexterous hands | 32 DOF |
| Payload | ~3 kg single-arm payload | Not recorded |
| Maximum speed | 6.1 km/h (~1.7 m/s) walking speed | 2 m/s |
| Runtime | ~3 hours | ~2 hours |
| Locomotion / control | Bipedal locomotion; whole-body control; teleoperation | Autonomous navigation; dynamic balance; human-like gait |
| Sensors | Monocular camera; 6-axis IMU; 360° microphone array; tactile sensors | 360° LiDAR; Intel RealSense D435; 6 stereo cameras; IMU |
| Special capability | Full-Sense Interaction System; tactile interaction; voice interaction; hot-swappable batteries; optional dexterous hands | NVIDIA + Intel processors; reinforcement/imitation learning; ROS-compatible SDK |
| Compute | AMD Ryzen 7 8845HS; optional Jetson AGX Orin/Thor configurations | NVIDIA + Intel processors |
| Availability | Commercial/developer platform | Commercially available |
| Price | Contact vendor | US$20,000–30,000 |
How They Compare
In terms of role, Fourier GR-3 and EngineAI SE01 are both full-size bipedal humanoids, but their application focus differs. Fourier positions GR-3 around interactive companionship and human-robot interaction, particularly in public-service and care-oriented environments. EngineAI SE01 has a stronger focus on manufacturing, logistics, research and education.
Their physical specifications also differ. GR-3 stands approximately 165 cm tall and weighs around 71 kg, compared with SE01 at 170 cm and 55 kg. GR-3 offers up to 55 degrees of freedom when configured with its optional 12-DOF dexterous hands, while SE01 is recorded with 32 DOF.
GR-3 has a recorded walking speed of 6.1 km/h, or roughly 1.7 m/s, while SE01 is recorded at up to 2 m/s. GR-3 has an average runtime of approximately three hours, compared with around two hours for SE01.
Manipulation is another point of differentiation. Fourier specifies an approximately 3 kg single-arm payload for GR-3 and offers either 6-DOF or optional 12-DOF dexterous hands. A comparable arm-payload figure is not recorded for SE01.
The robots also take different approaches to perception. GR-3 combines a monocular camera, 6-axis IMU, 360-degree audio pickup and tactile sensors distributed across its head and torso. Its Full-Sense Interaction System combines vision, hearing and touch to support more natural human-robot interaction. SE01 is recorded with a 360-degree LiDAR, Intel RealSense D435, six stereo cameras and an IMU.
GR-3 additionally supports immersive teleoperation, voice interaction, hot-swappable batteries and an AMD Ryzen 7 8845HS processor, with higher-performance computing options including NVIDIA Jetson AGX Orin or Thor.
Summary
Fourier GR-3 and EngineAI SE01 occupy the same broad full-size humanoid category but emphasize different capabilities. GR-3 places greater emphasis on human interaction, tactile and voice-based engagement, dexterity and care-oriented applications, while SE01 is positioned more toward industrial, logistics, research and educational applications.
The comparison also shows significant hardware differences: GR-3 provides up to 55 DOF, a 3 kg single-arm payload and approximately three hours of runtime, while SE01 is lighter, has a higher recorded maximum speed and uses a perception suite built around LiDAR and multiple vision sensors.
The figures above should be read as a direct comparison of the currently documented specifications rather than as a broader assessment of either platform.
More articles on this topic
52 articles ReportPUDU BellaBot vs. UBTECH CADEBOT L100
 ReportPudu CC1 vs. KEENON KLEENBOT C30
 ReportDEEPRobotics Lynx M20 vs. Unitree B2-W
 ReportDEEPRobotics X30 Pro vs. Unitree B2
 ReportServe Robotics Delivery Robot vs. Cartken Courier
 ReportElliQ vs. LOVOT
 ReportLOVOT vs. PARO
 ReportKEENON BUTLERBOT W3 vs. Relay+
 ReportPUDU FlashBot vs. Relay+
 ReportPARO vs. Joy for All Companion Pet Cat
 ReportServe Robotics Delivery Robot vs. Starship Delivery Robot
 ReportCartken Courier vs. Kiwibot
BUSINESS NEWS WEEKLY LETTER
The Weekly Letter for Robotics Professionals, Summarizing the Most Important Industry Moves, Launches, Deals and Signals.