Scientists Teach Humanoid to Climb Ladders and Survive Falls
With a 92.5% success rate in simulations, the new approach could reduce the need to train systems for every physical challenge.
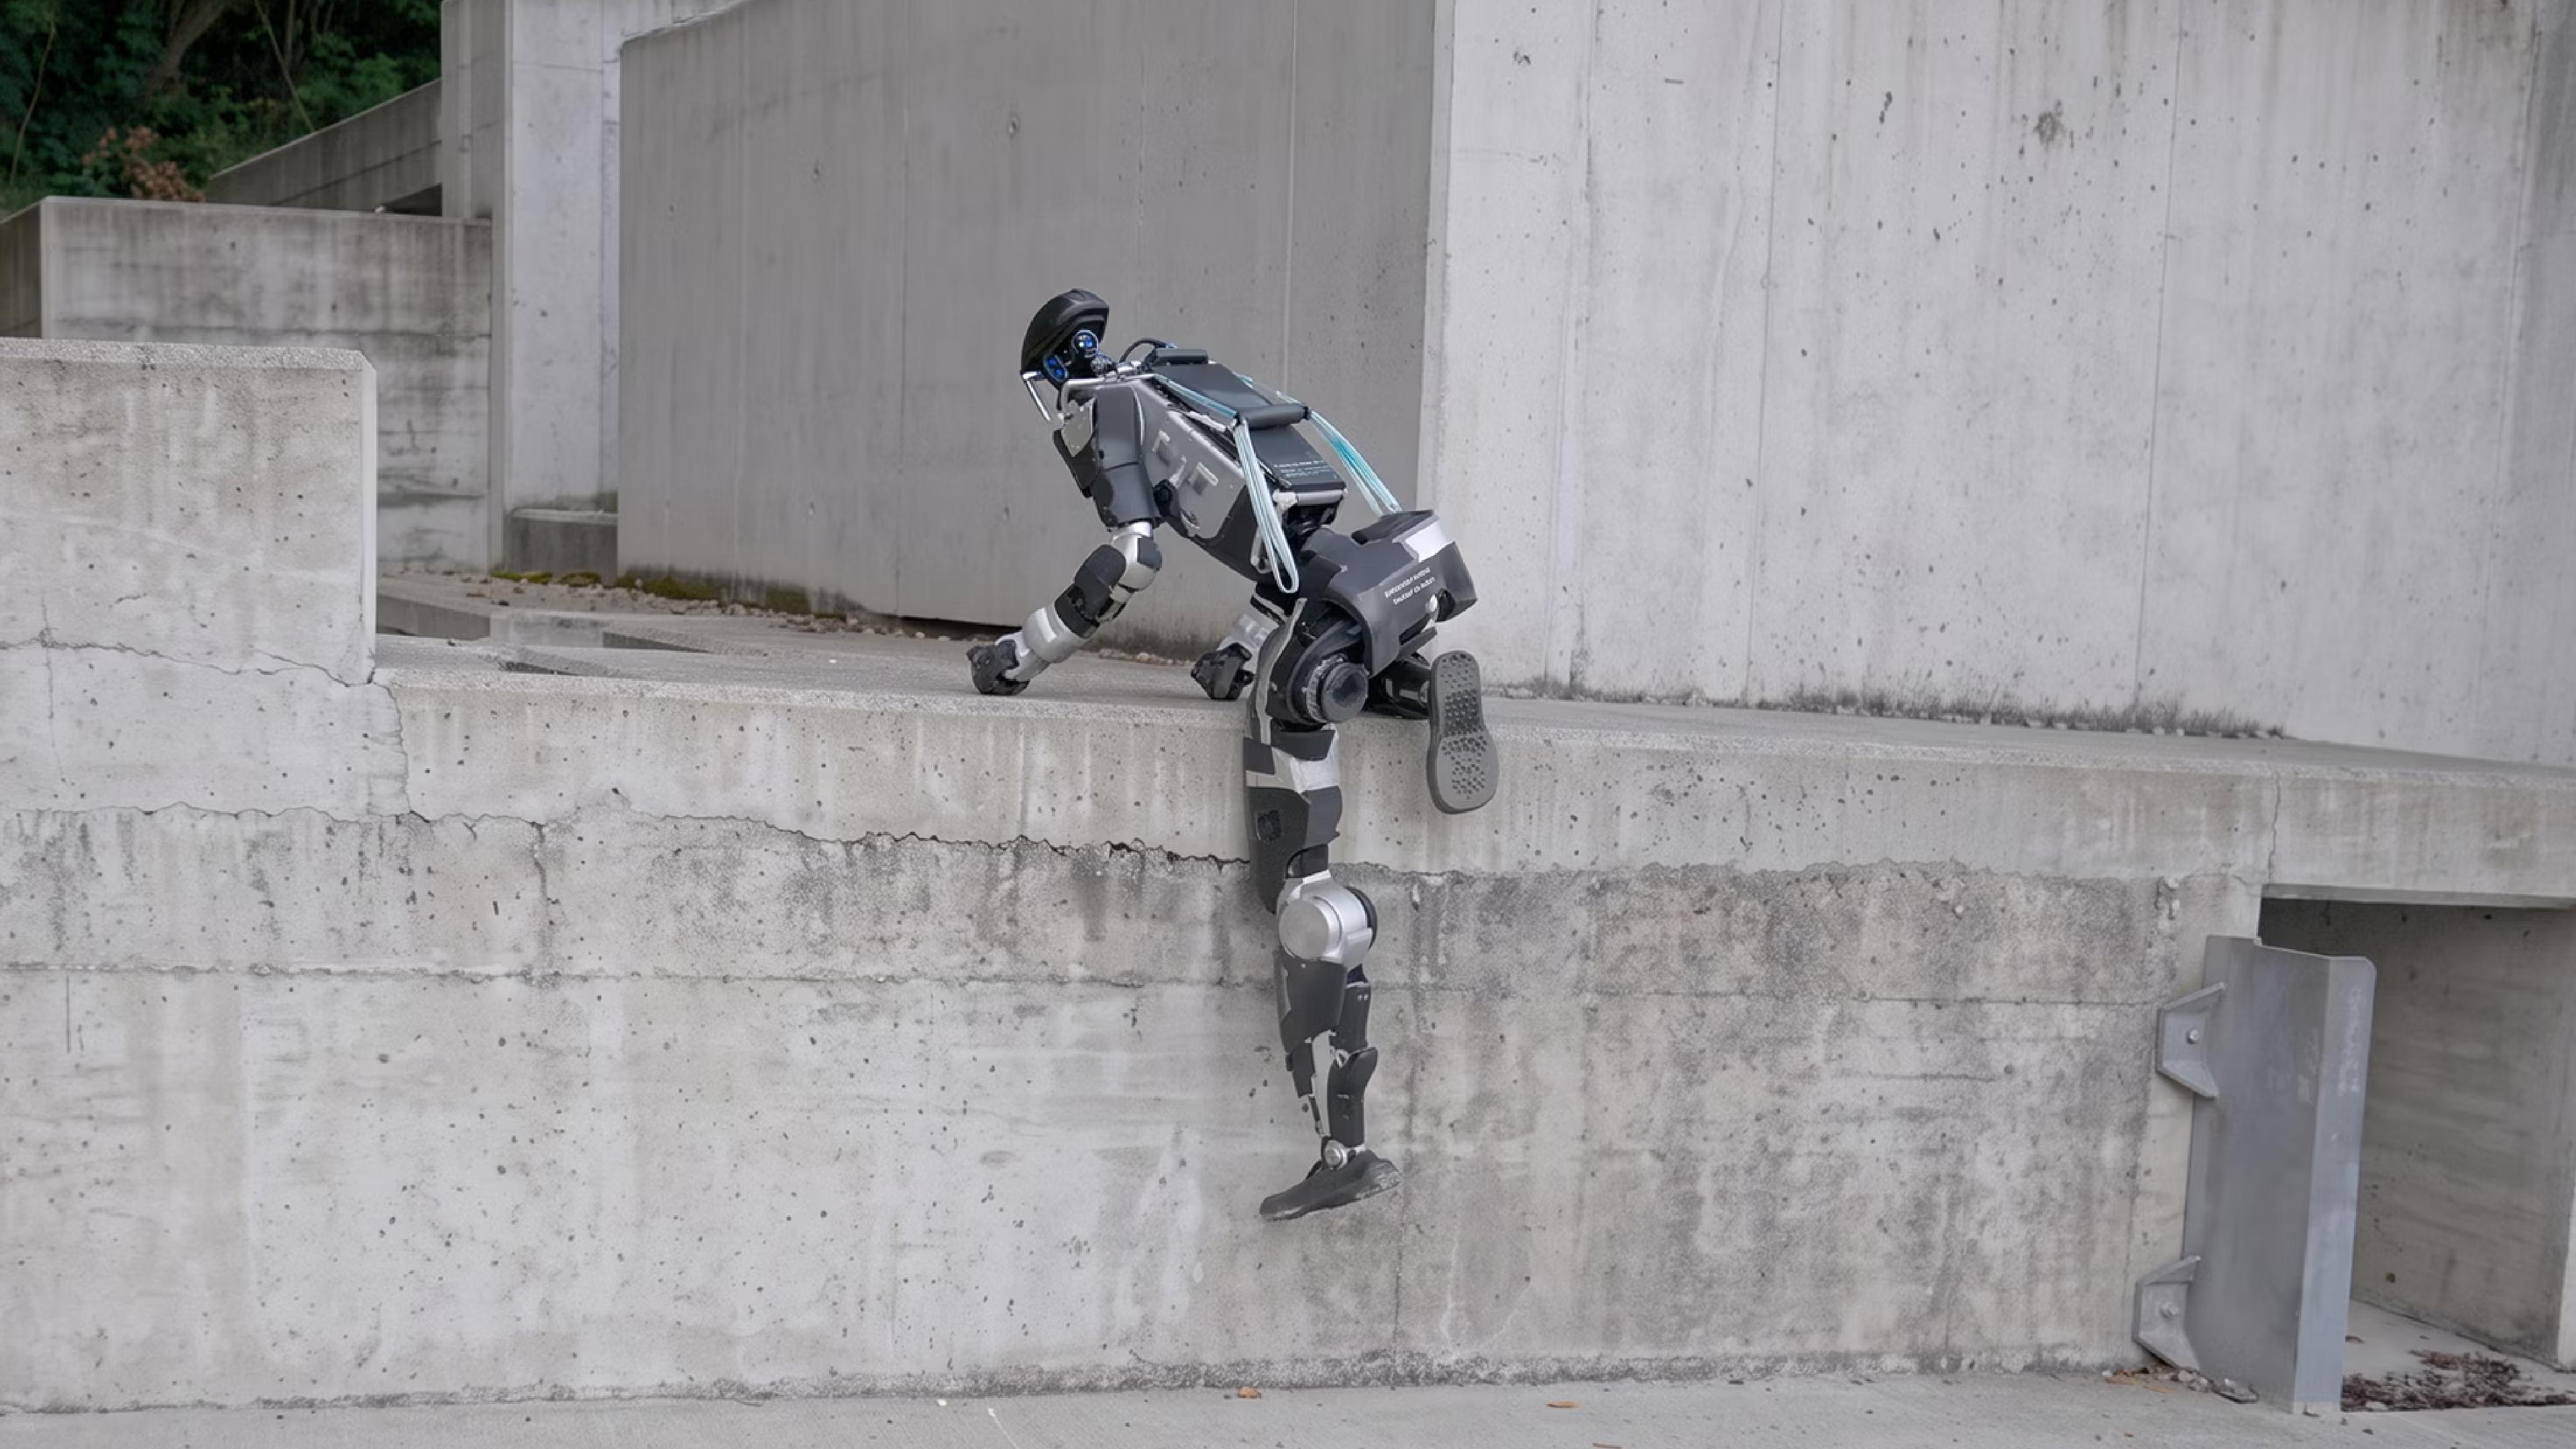
With a single movement controller, an AI system developed by ETH Zurich researchers enables a humanoid robot to scale ladders, overcome obstacles and recover itself after a fall.
The work was demonstrated on a Unitree G1 humanoid and detailed in a research paper on October 22; and the technology has been named Attention-based Contact Planning (ACP). ACP is not like the conventional method of having distinct movement patterns for each task. It is up to the robot to determine what part of its body will make contact with the environment before coordinating the movements needed to proceed.
To instill the system with various contact patterns, the team used just 13.2 minutes of human motion data and paired it with reinforcement learning for greater adaptability. The result is a controller capable of handling multiple physical challenges, from climbing stairs or vaulting over an obstacle to crossing stepping stones and rising from a fall.
What sets the robot apart is its approach to planning. Rather than imitate a human’s sequence of actions, the system ascertains where hands, feet and knees need to be placed for support while moving toward a target.
A LiDAR sensor on the robot’s head will map the terrain, allowing it to identify good contact points, then two neural networks translate that information into coordinated movement. One of them has the job of controlling the 23 joints, while the other predicts contact for nine body parts in the next 1.5 seconds. Running at 50 hertz onboard, the networks mean the robot does not have to keep going back to prerecorded demonstrations to make adjustments.
In a simulation of eight obstacle courses, ACP reported a 92.5% average success rate, improving from the 58.8% an older method would yield, though these results were obtained under controlled simulation conditions and do not represent the robot's success rate in physical environments.
That said, the researchers also demonstrated the system on an actual Unitree G1, with the robot shown to recover from missteps and make its way over difficult terrain and onto platforms.
With such capabilities, it’s pretty clear to see how such a system could allow humanoids to function in human spaces with their uneven surfaces and ladders, but the scope of this research is limited to the obstacles at hand, not to charting a course through an unknown workplace or building. Nor do the demonstrations tell how reliable the robot will be over time.
Still, the evidence suggests that if you can teach a humanoid to coordinate with its surroundings, it becomes more versatile, reducing the need to develop separate movement controllers for every new obstacle.
More articles on this topic
235 articles ReportWhat it Really Costs to Own a Personal Assistant Robot at Home
 ReportA Little Company, Courtesy of a Robot
 ReportA Humanoid Walks into a New York Park
 ReportRailway Inspection Robots Search for Defects in Tracks
 ReportChina's Humanoid Supply Chain Moves Toward Industrial Production
 ReportCompanionship now comes with a Charging Cable
 ReportCould a Robotic Guide Help Blind Travelers Navigate Public Spaces?
 ReportThis Robot Finds Cracks and Fixes Them
 ReportXPENG's IRON Humanoid Adapts to Changing Human Gestures in Real Time
 ReportRobots Are Learning to Sort Clothes for Textile Recycling
 Report110 Humanoid Robots Set Guinness World Record With Synchronized Dance
 ReportThe Robot to Fill Potholes and Change How Road Repairs are Done
BUSINESS NEWS WEEKLY LETTER
The Weekly Letter for Robotics Professionals, Summarizing the Most Important Industry Moves, Launches, Deals and Signals.